Robotic Gas Sensing

Gas Source Localization with a Vertical Take-Off and Landing Drone

Measurment Campaign at Mount Etna, Italy
Our Research Topics in Robotic Gas Sensing
While the foundations of robot olfaction are established, the practical application of mobile gas sensing is often constrained by the chaotic nature of gas dispersion and the complexity of real-world environments. To overcome these challenges, our current work addresses existing limitations by investigating more robust sensing modalities, such as advanced sensor architectures and multimodal data fusion.
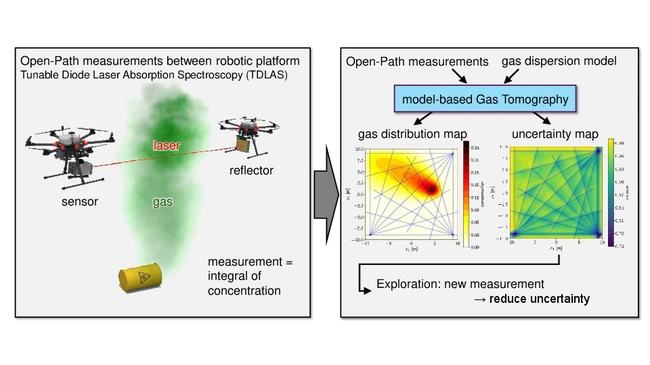
In the FlyMoGaTo project, the goal is to perform laser absorption measurements between two flying drones to measure gases and trace substances in the air, without the drone rotors disturbing the gas distribution. For this purpose, models of the gas distribution are created from the (remote) measurements using partial differential equations known from physics, and based on these models, intelligent measurement plans are calculated. Our objective is to create the most accurate spatial map of the gas distribution as efficiently as possible.
FlyMoGaTo is part of the DFG SPP2433 (https://www.uni-bremen.de/spp-2433).

On a micro scale, gas dispersion is inherently chaotic. On a larger scale, however, it depends on a multitude of environmental factors, most notably the geometry of the search area and airflow conditions. Traditionally, robotic olfaction has relied on simplified assumptions – such as uniform wind fields across a known domain – to make the problem more tractable. However, when transitioning from controlled laboratories to realistic gas source localization scenarios, these simplifications rarely hold and therefore limit the applicability of such methods.
Our research aims to reduce this dependence on prior knowledge, enabling robots to sense the physics of their surroundings beyond mere gas concentration. Currently, we investigate how sample-based airflow estimation methods can be meaningfully incorporated into the localization process. Transitioning to a multimodal framework allows us to exploit a broader range of environmental information, grounding our algorithms in domain-specific measurements rather than static assumptions. Looking forward, we expect this approach to be a key enabler for robust gas sensing in complex, off-laboratory deployments.

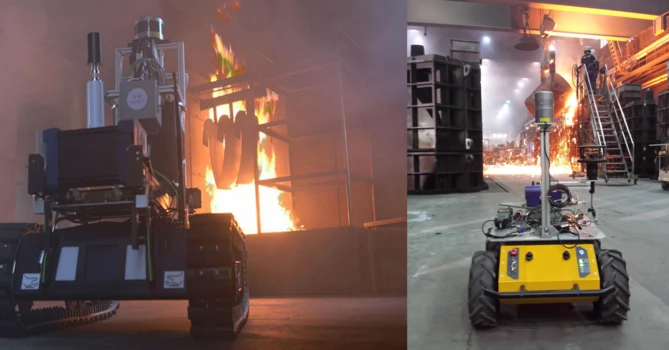
In robotic gas sensing, also known as robot olfaction, we aim to equip mobile platforms like rovers and drones with a digital sense of smell. These systems are designed for disaster relief and environmental monitoring, as robots can operate where human safety is at risk or accessibility is limited. To this end, our systems must be able to autonomously detect hazardous gases, create distribution maps, and locate potential leaks. We achieve this by developing specialized exploration algorithms that leverage multiple sensor technologies, e.g. for measuring gas concentrations or wind speeds and directions.